Work

Professional and research experience. Each entry summarizes the context and what I worked on; the linked pages go into the engineering.

  • Robotic Fabrication at Valstad Shipworks
    Valstad Shipworks · Austin, TX · May – Aug 2026

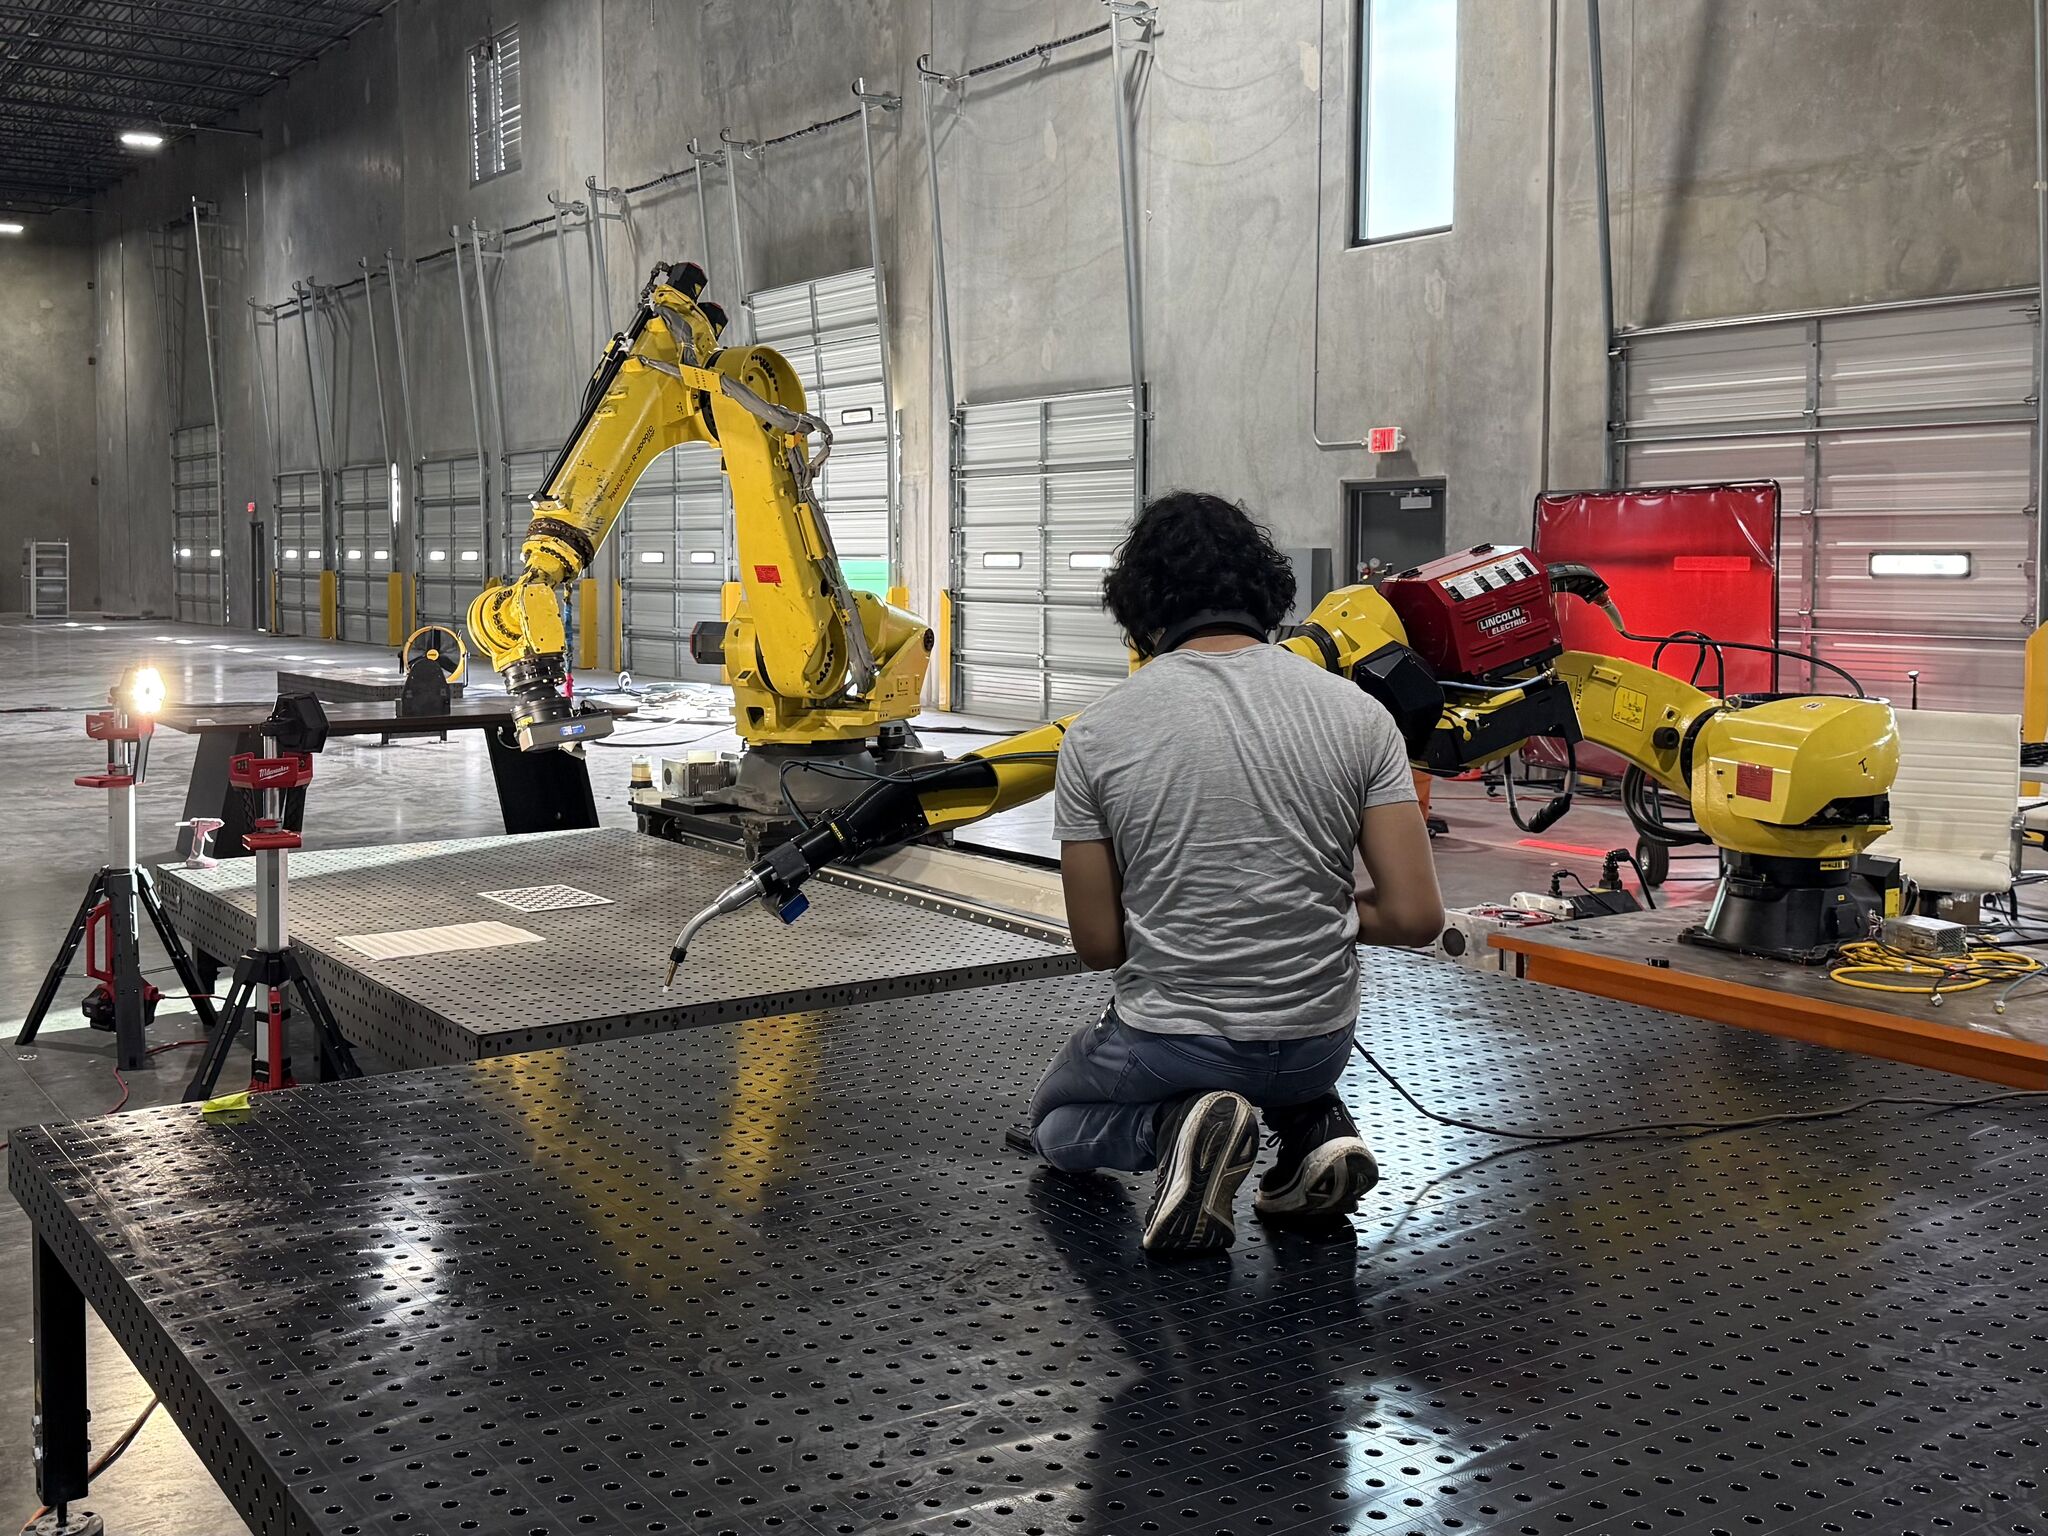
    Robotic Fabrication at Valstad Shipworks

    Robotics Engineering Intern

    Hardware and software for a robotic ship-panel welding cell built around FANUC M-710 robots on a Güdel linear axis. I worked on calibrating and integrating the cell hardware, designed tooling and interface parts for it, and wrote software that turns ship CAD into fabrication data and records what the robots did.

    • FANUC operation from the teach pendant; TCP and work-table calibration; EOAT changes
    • Magnetic EOATs, sensor mounts, calibration tooling, and an M-710-to-RTU adapter plate, with drawings and vendor RFQs
    • CAD-to-fabrication software on OpenCASCADE (OCP) and CadQuery: panel decomposition, laser DXFs, part IDs and markings
    • Weld planning: ported the team's joint-detection and stitch-placement pipeline; wrote the torch-reach obstruction and consumables models
    • Robot telemetry: producer-side instrumentation and a Rust/TypeScript replay viewer with 3D playback
    • Cell simulator profiling (contributor): step time 36.7 ms → 5.9 ms
  • Humanoid Robotics at LIDAR
    Georgia Tech LIDAR · Atlanta, GA · Sep 2025 – May 2026

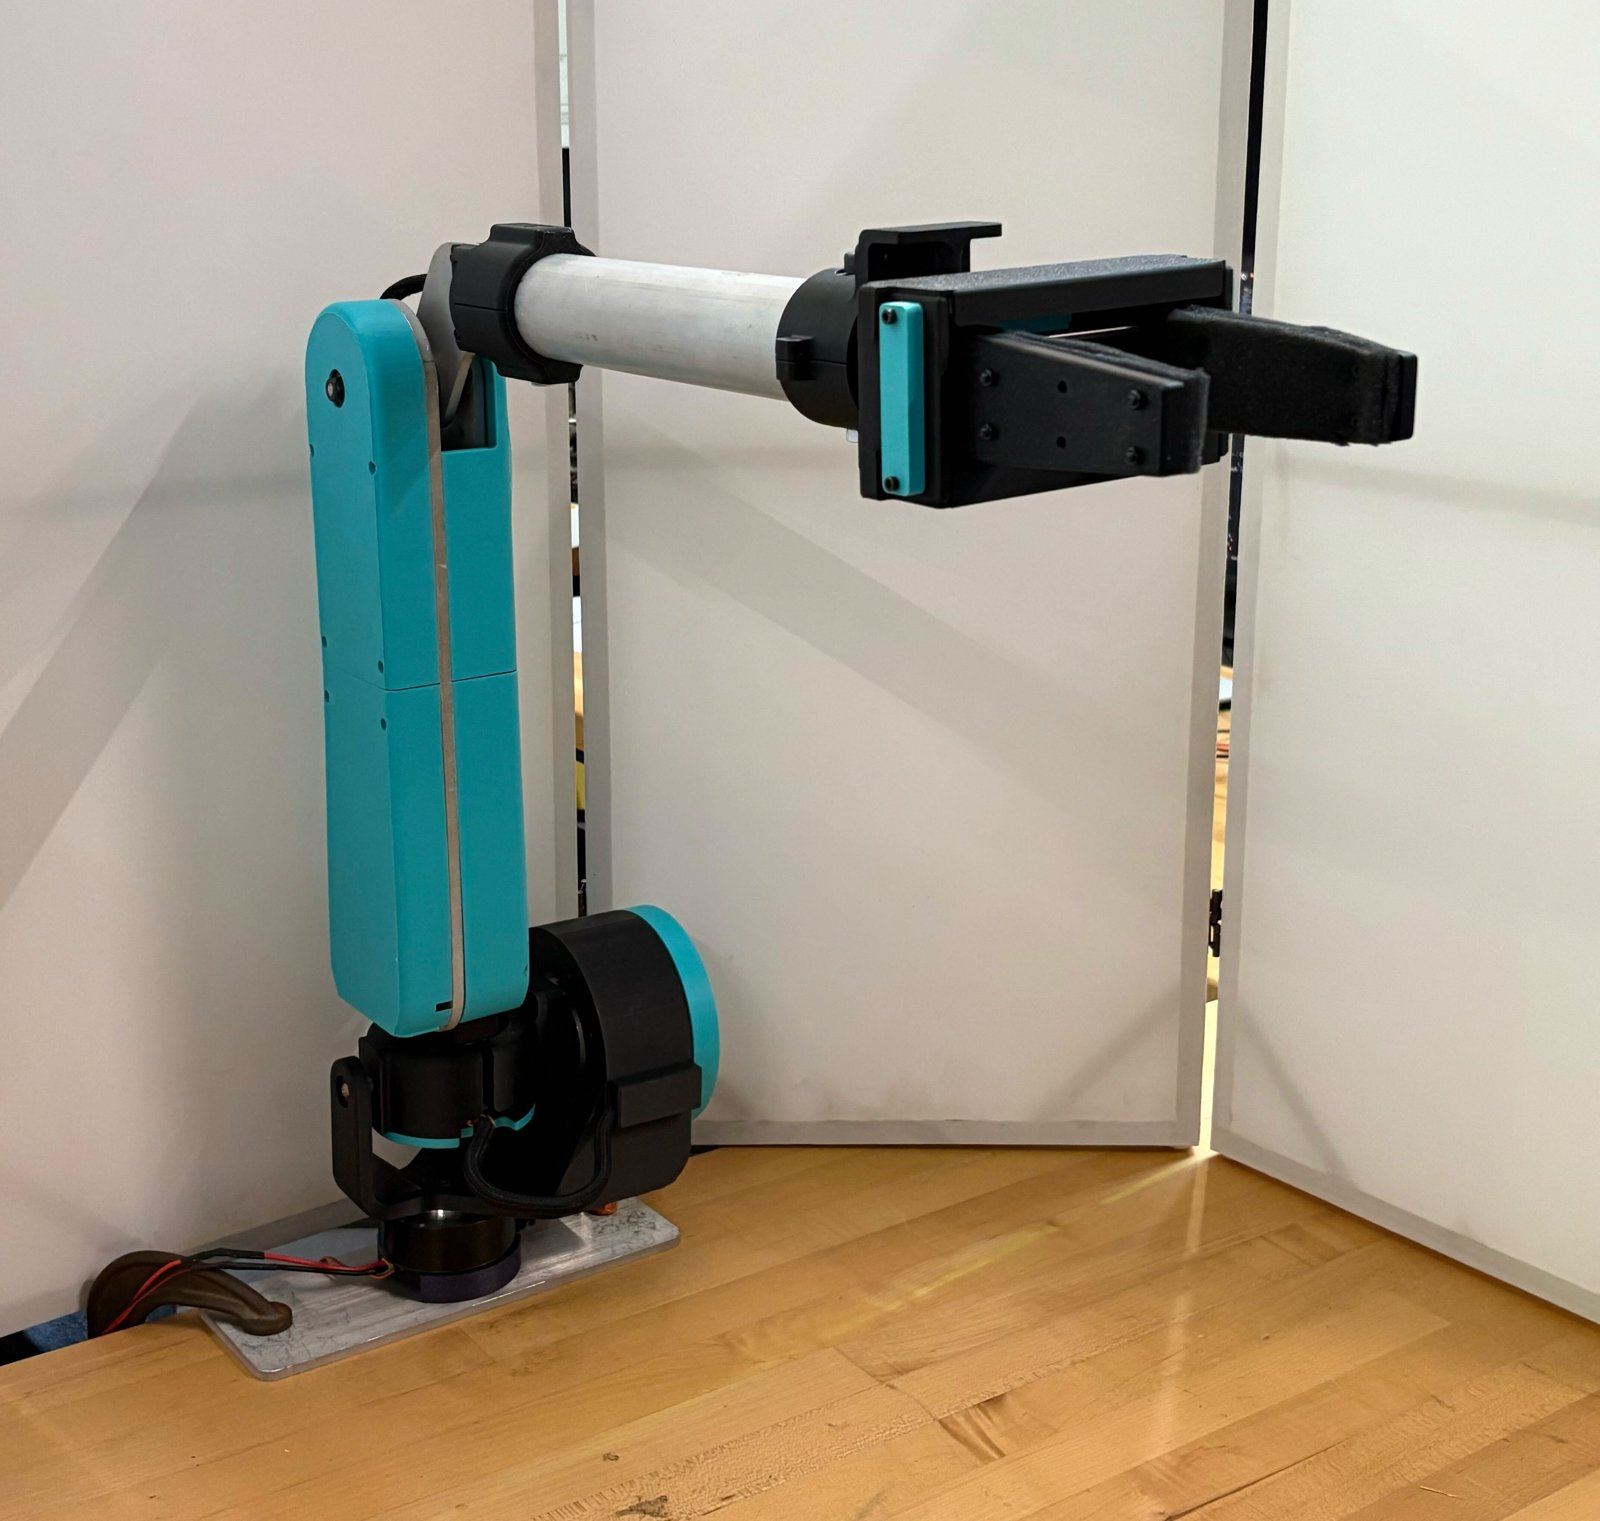
    Humanoid Robotics at LIDAR

    Undergraduate Research Assistant

    Hardware for a custom auxiliary arm mounted on an Agility Robotics Digit humanoid. I redesigned the arm's gripper (prototyped, not mounted), prototyped tactile sensing for it, and did much of the arm's wiring and assembly.

    • Gripper redesign: dual-servo crank–four-bar parallel jaw, 6.6 in stroke
    • Tactile-sensing prototyping (magnetometer arrays, unfinished)
    • XT30 power and CAN harness fabrication for the arm
    • Arm assembly and electrical/mechanical integration
    • Humanoid calibration and motion-validation support
Earlier
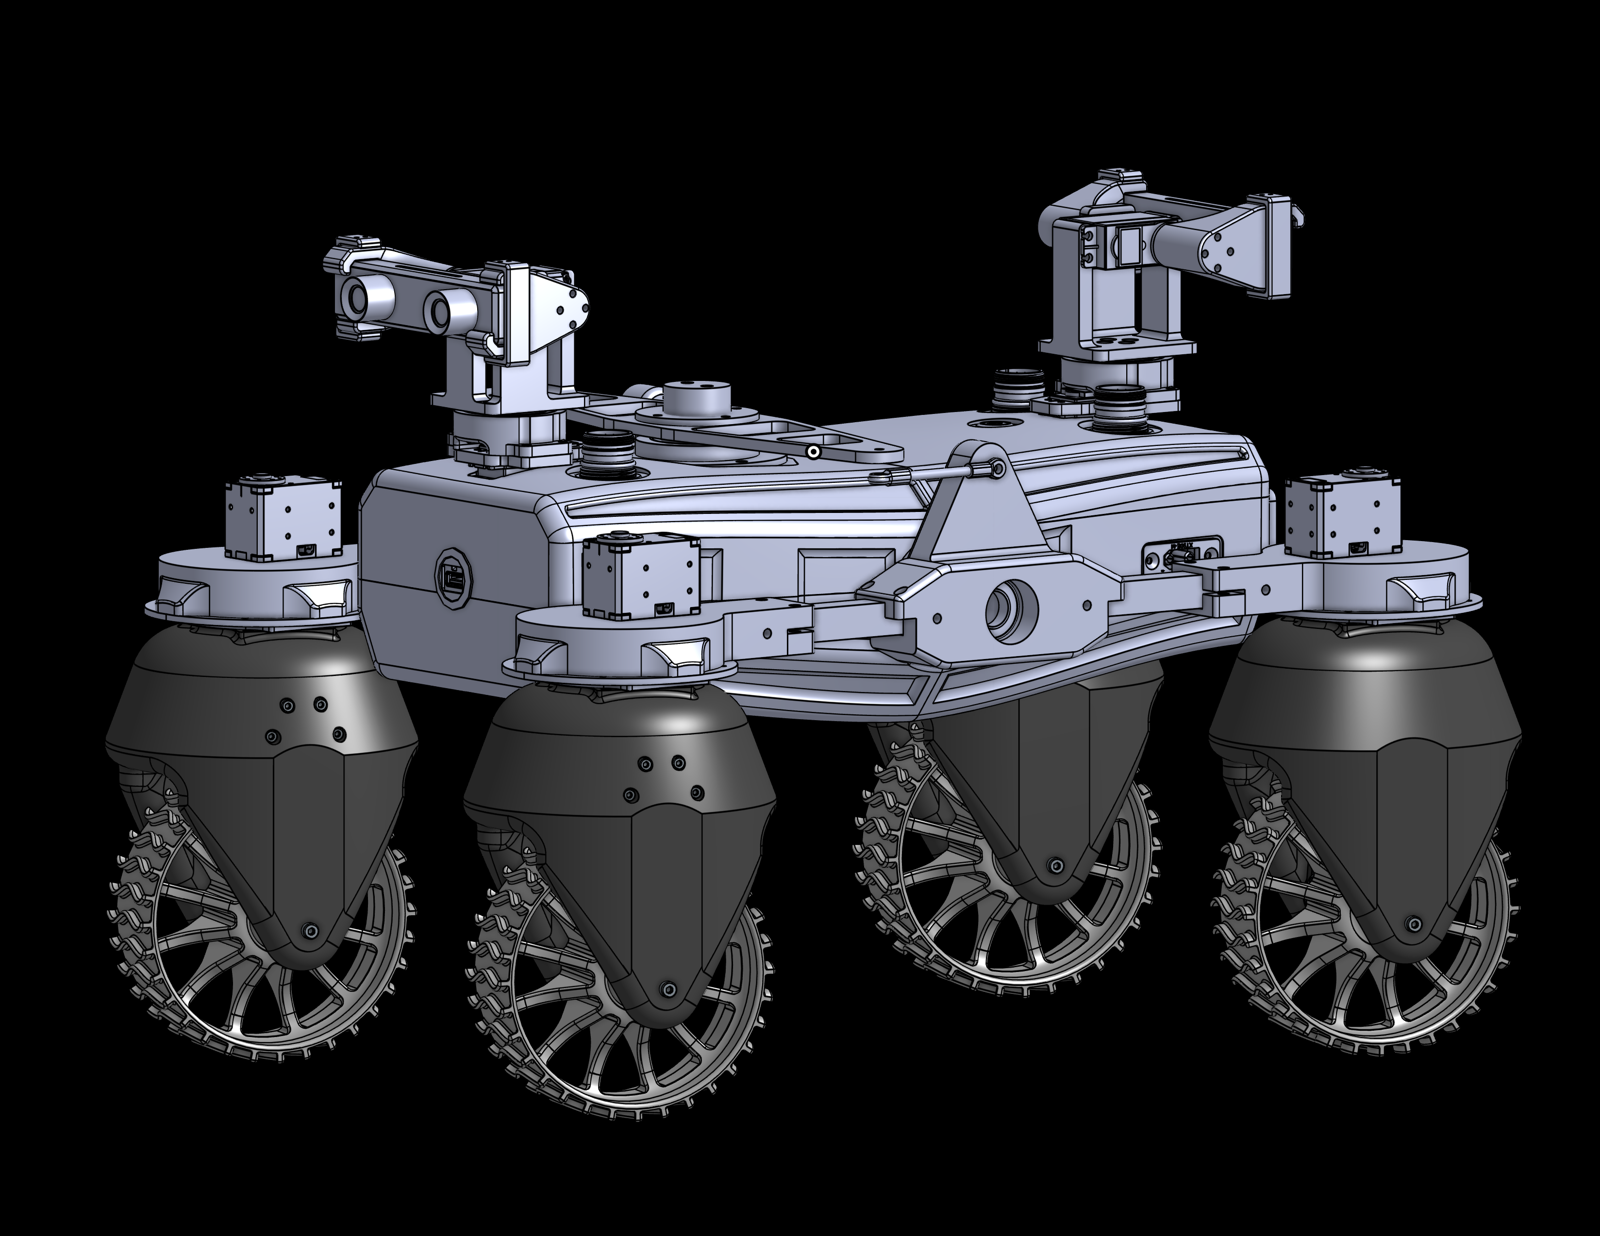
  • Rover Drive Module at the Aerospace Robotics Lab
    Georgia Tech Aerospace Robotics Lab · Sep – Nov 2025

    Rover Drive Module at the Aerospace Robotics Lab

    Undergraduate Research Assistant

    Mechanical redesign of a holonomic drive module for a small rover used as a robotics test platform: packaging and integration of the wheel and drive assembly. About two months.