Context
The Aerospace Robotics Lab (Yashwanth Nakka) has a small four-wheeled rover that the group uses as a test platform for robotics software and autonomy work. I spent about two months in fall 2025 on its mechanical side, mainly the corner drive modules.
Drive module redesign
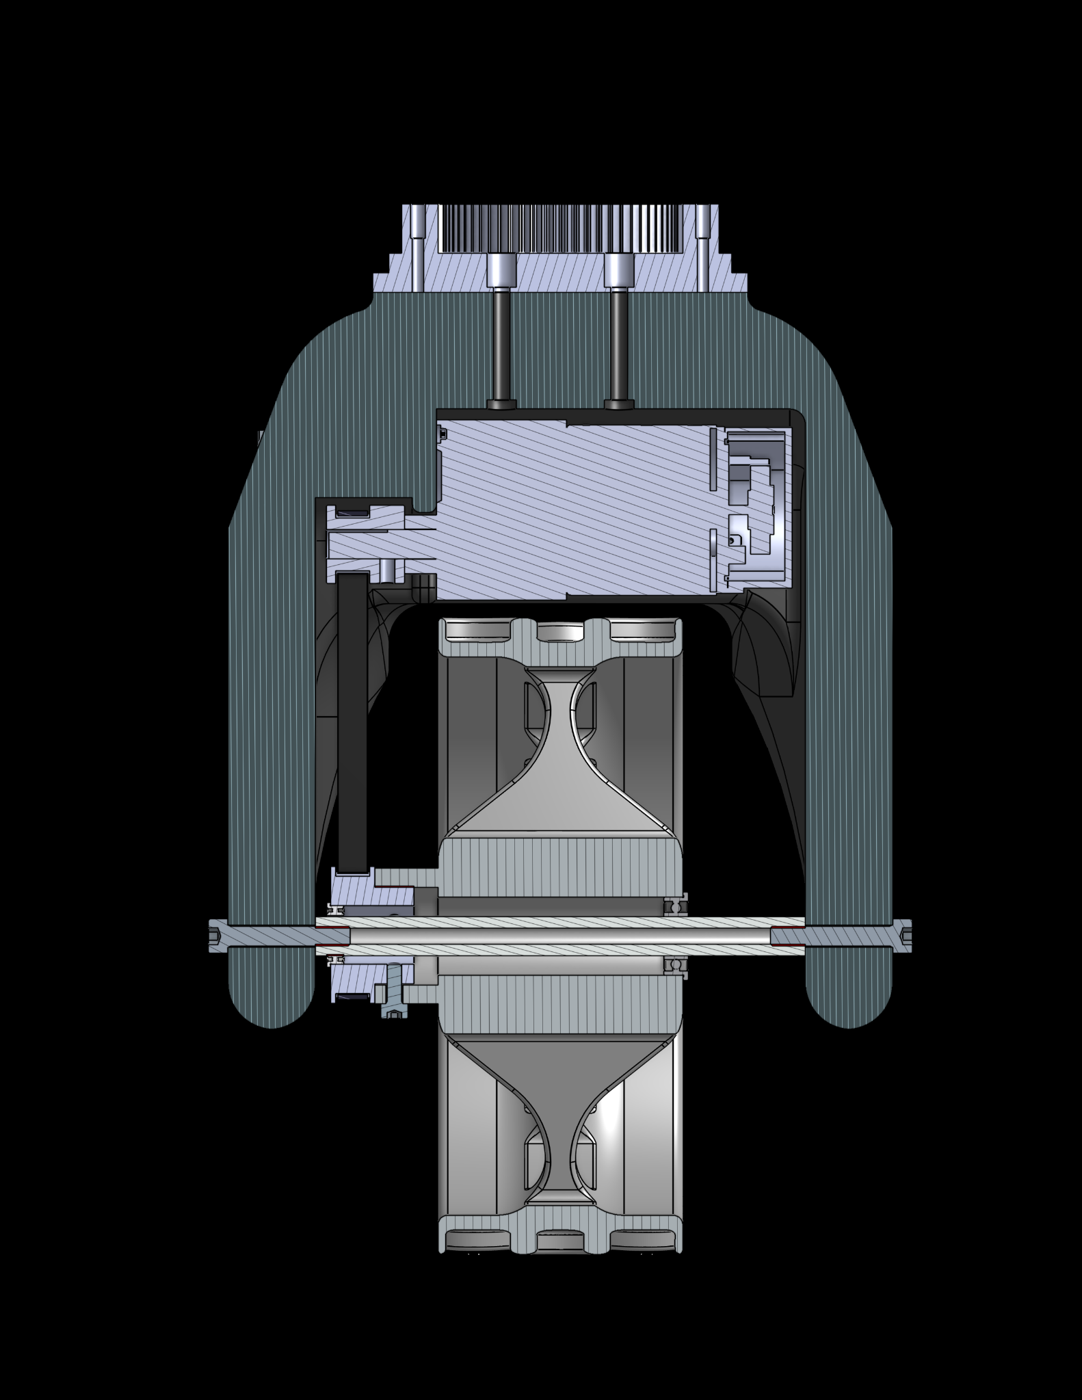
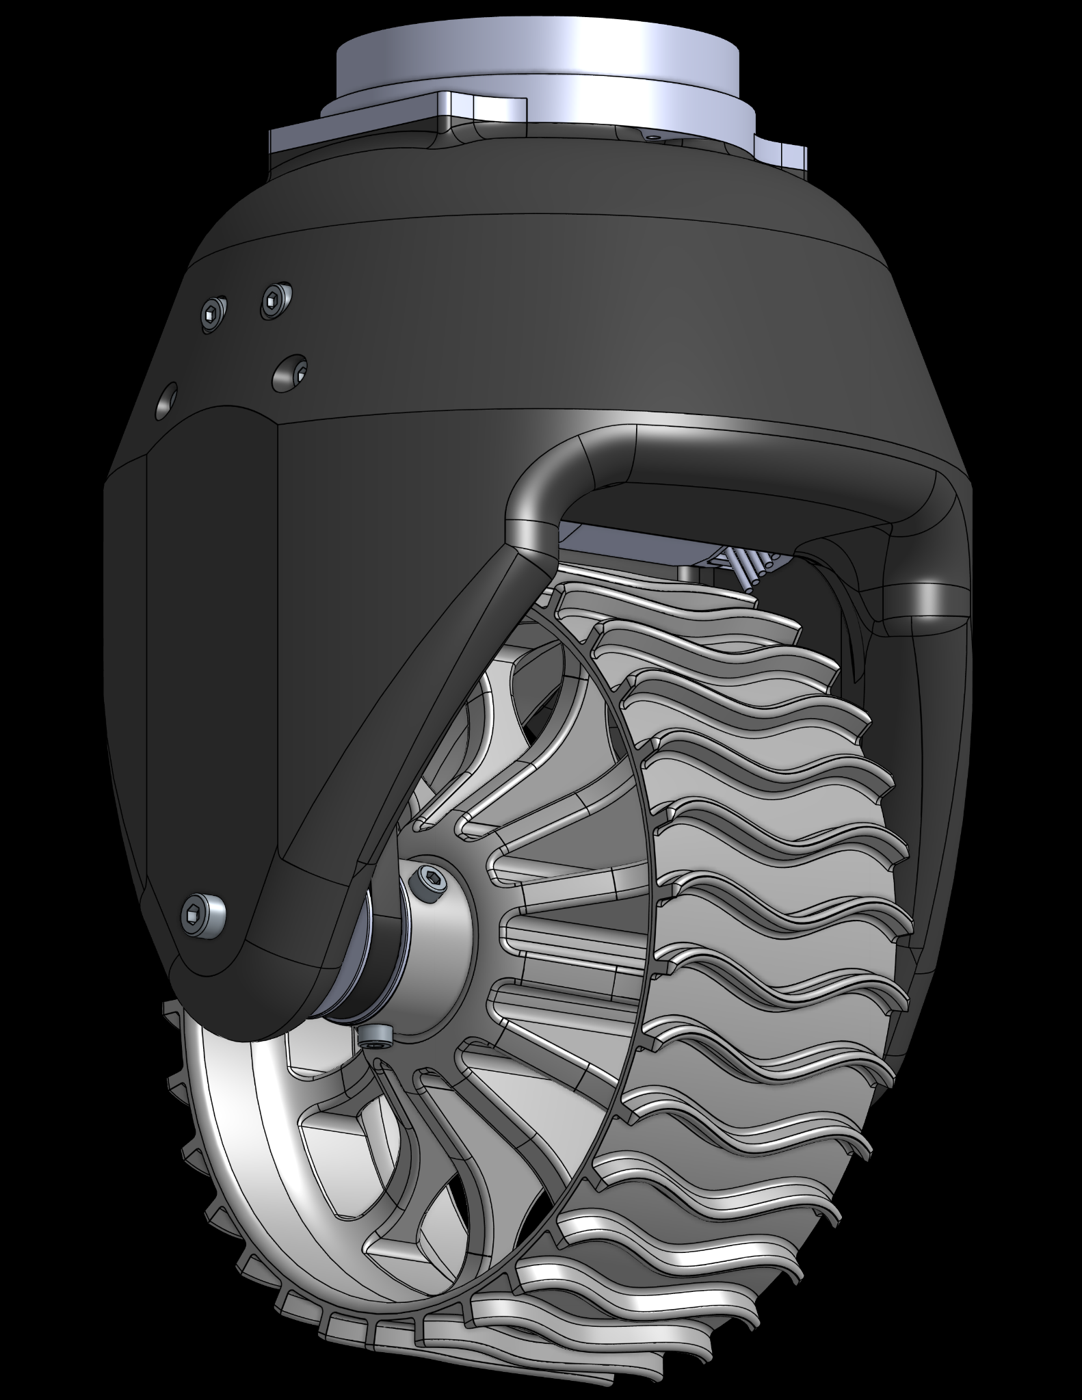
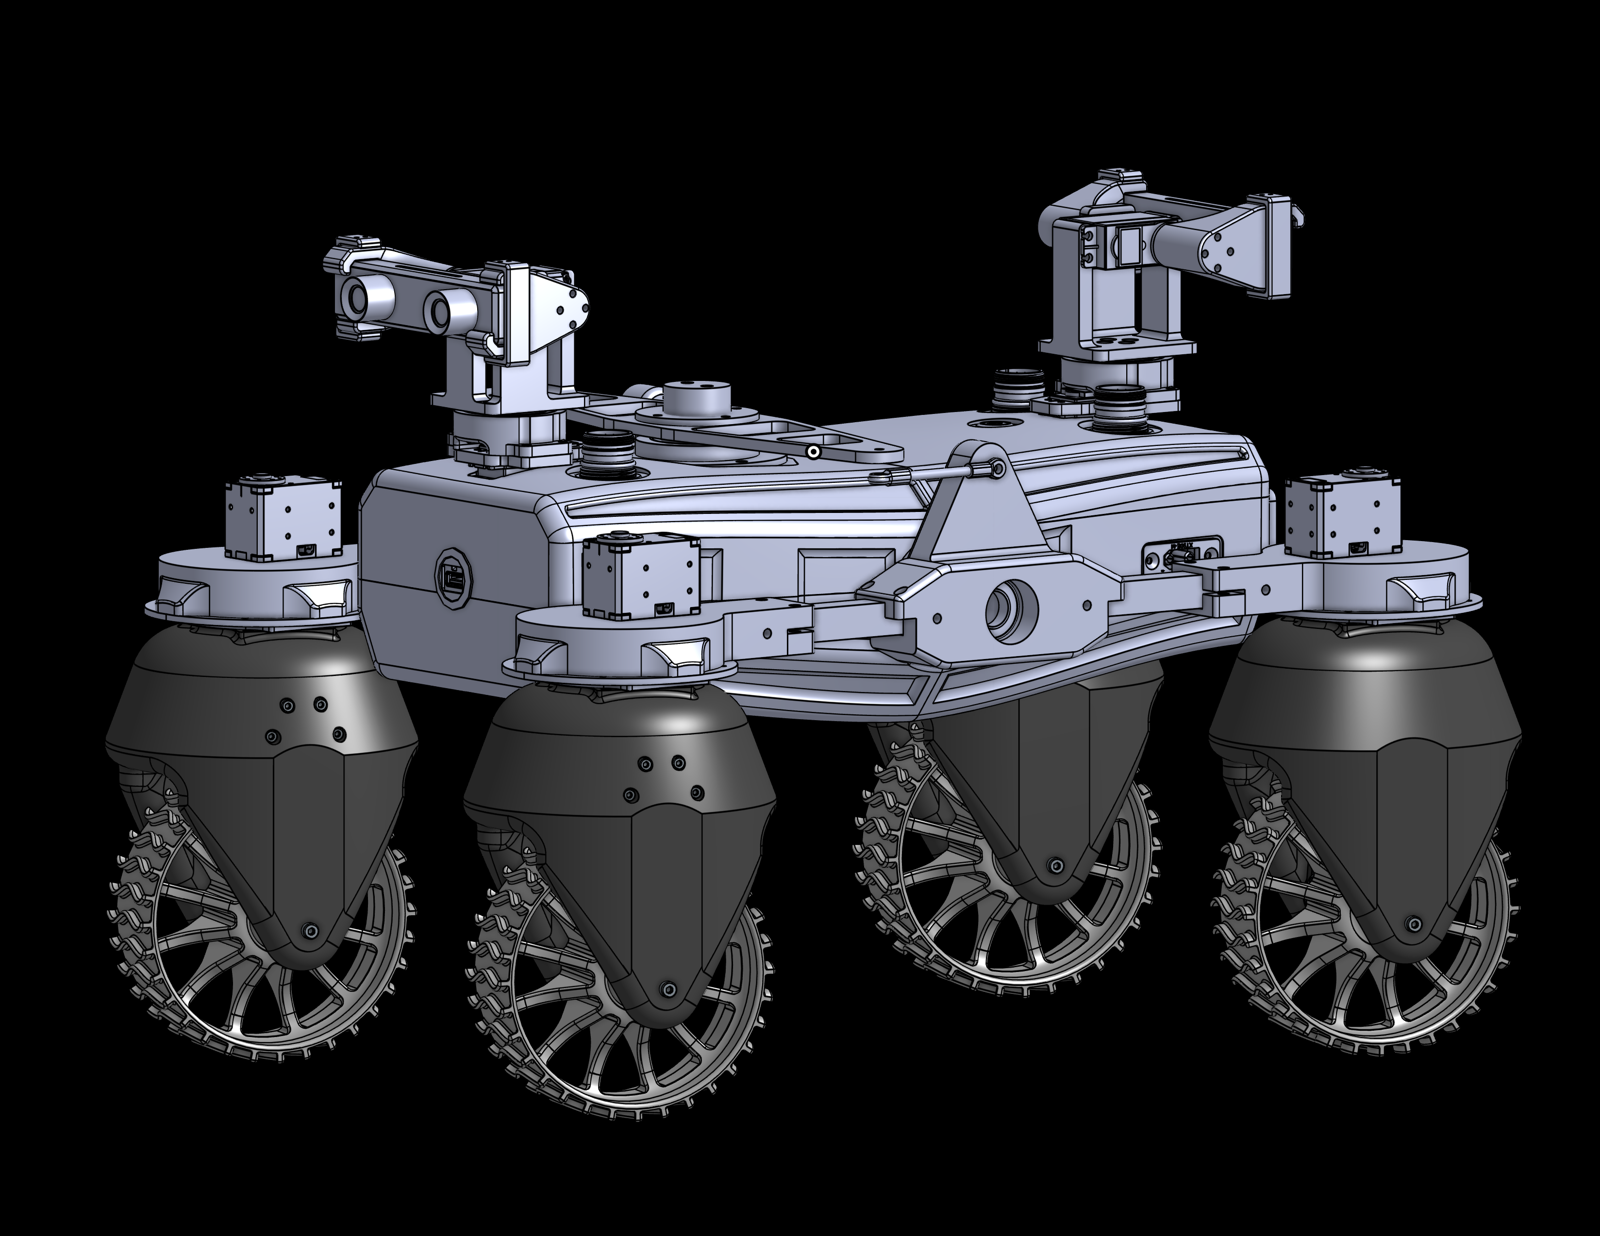
Each corner of the rover is a holonomic drive module: a wheel and its drive hardware packaged into one unit. I redesigned the module’s structure from two L-brackets into a single shell so the module is easier to service and swap as a unit. The work was packaging and integration: fitting the drive hardware, shafts, and wheel into the shell and getting its mounting interface to the chassis right.
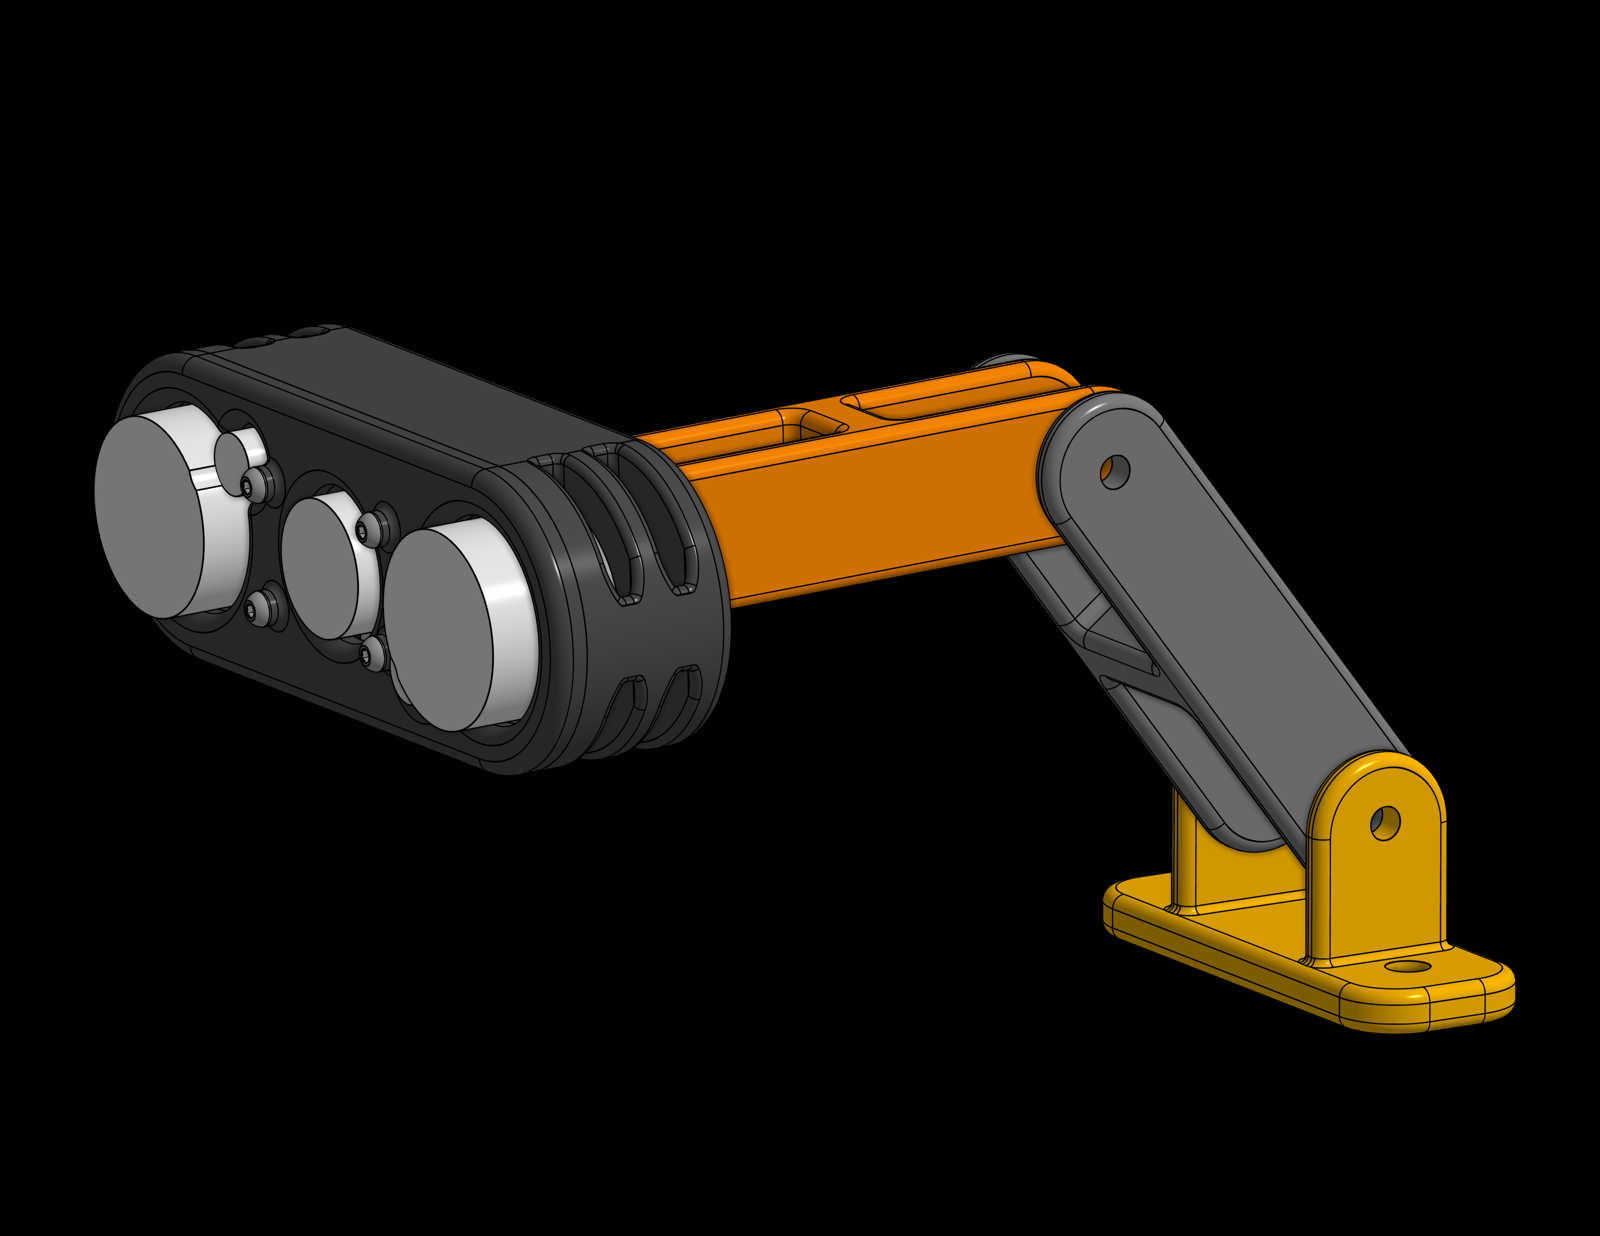
I also designed an articulated camera mount, a multi-joint arm that positions a compact camera head relative to a fixed base, used to test vision-sensor placement and alignment.
Scope
This was a short, mechanical-only contribution to a platform the lab already had. The rover’s software, autonomy work, and the rest of its hardware were the group’s.